
Modular Dual-State Knowledge Graph, 16-Step SDLC Tool Suite, and the RobOS foundation release
Laid the foundation of RobOS: a multi-package JSON-LD Knowledge Graph validated by W3C SHACL shapes, a complete desktop SDLC suite from C4 topology modeling to Kind Kubernetes auto-deploy, and the foundation release.
The first month of this two-month sprint established the core thesis of RobOS—that the Knowledge Graph is the product—and delivered the foundation release across the desktop appliance VM and native app suite:
- Modular Dual-State Knowledge Graph (
.robos/kgraphs/): Replaced monolithic config files with namespaced JSON-LD packages validated by W3C SHACL shapes and aligned with Schema.org, backed by Knowledge Graph Explorer (with an embedded Swagger-UI OpenAPI console and reviewed workspace imports), Schema Studio, and thekgraph-*skills CLI for semantic blast-radius diffing betweenmainand feature branches. - 16-Step Verified SDLC & Cloud-Init Onboarding: Automated first-boot QEMU/KVM provisioning with
robos-splashand unified GitHub onboarding; verified the 16-step Acme Petshop lifecycle across Task Planner, System Topology Studio (C4 + OpenAPI 3.1 synthesis), Git Projects, Bruno REST API Client, and Kube Studio (with real local Kind Kubernetes clusters and zero-click KGraph auto-deployment). - IDE Debugging Bridges, UHP Agent Routing & Prompt Security: Shipped the IntelliJ IDEA (port 63343 IPC) and VS Code breakpoint reproduction and PR review bridges, Agents Manager & Agent Chat with UHP
HarnessRouter, MCP OAuth, Caveman prompt compression, DSPy optimization, Remote Execution Studio (Bazel/Buck2/REAPI), and the zero-dependency Prompt Security Guard.
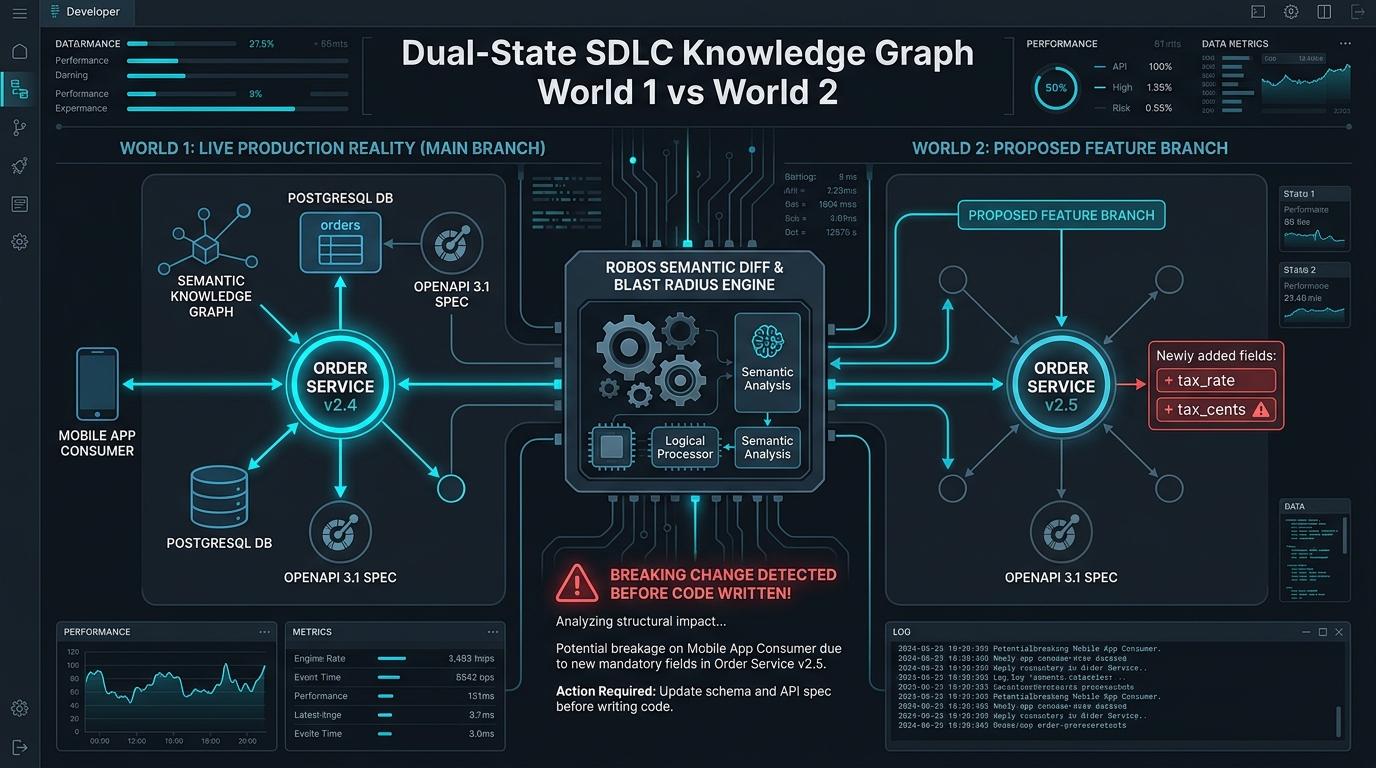
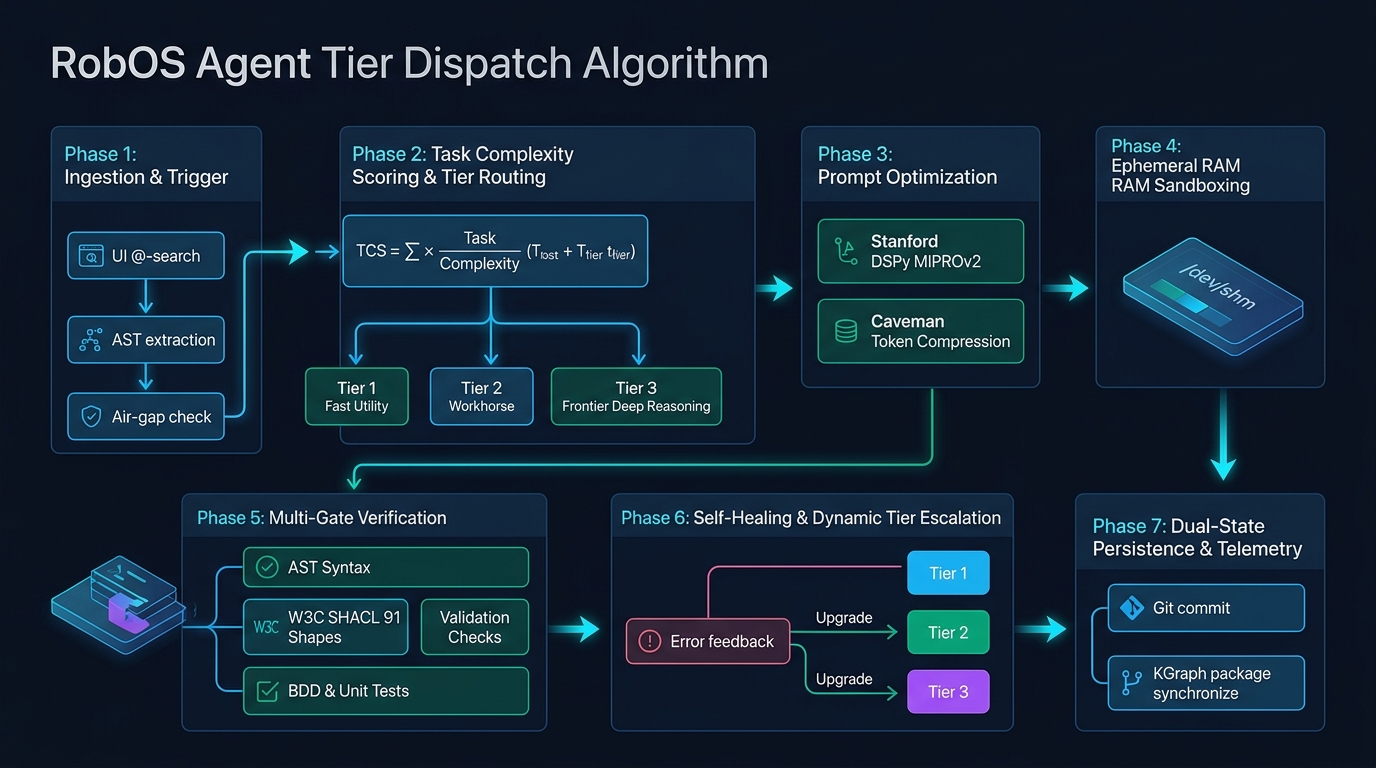
Knowledge Graph architecture →
16-Step SDLC walkthroughs →
Download RobOS v0.0.9 →
Commits: 73cb6441 · 194e2c8a · a90ae3f7 · 6f0e1605 · 1143d01c